RKRIBIK KHOTEJA
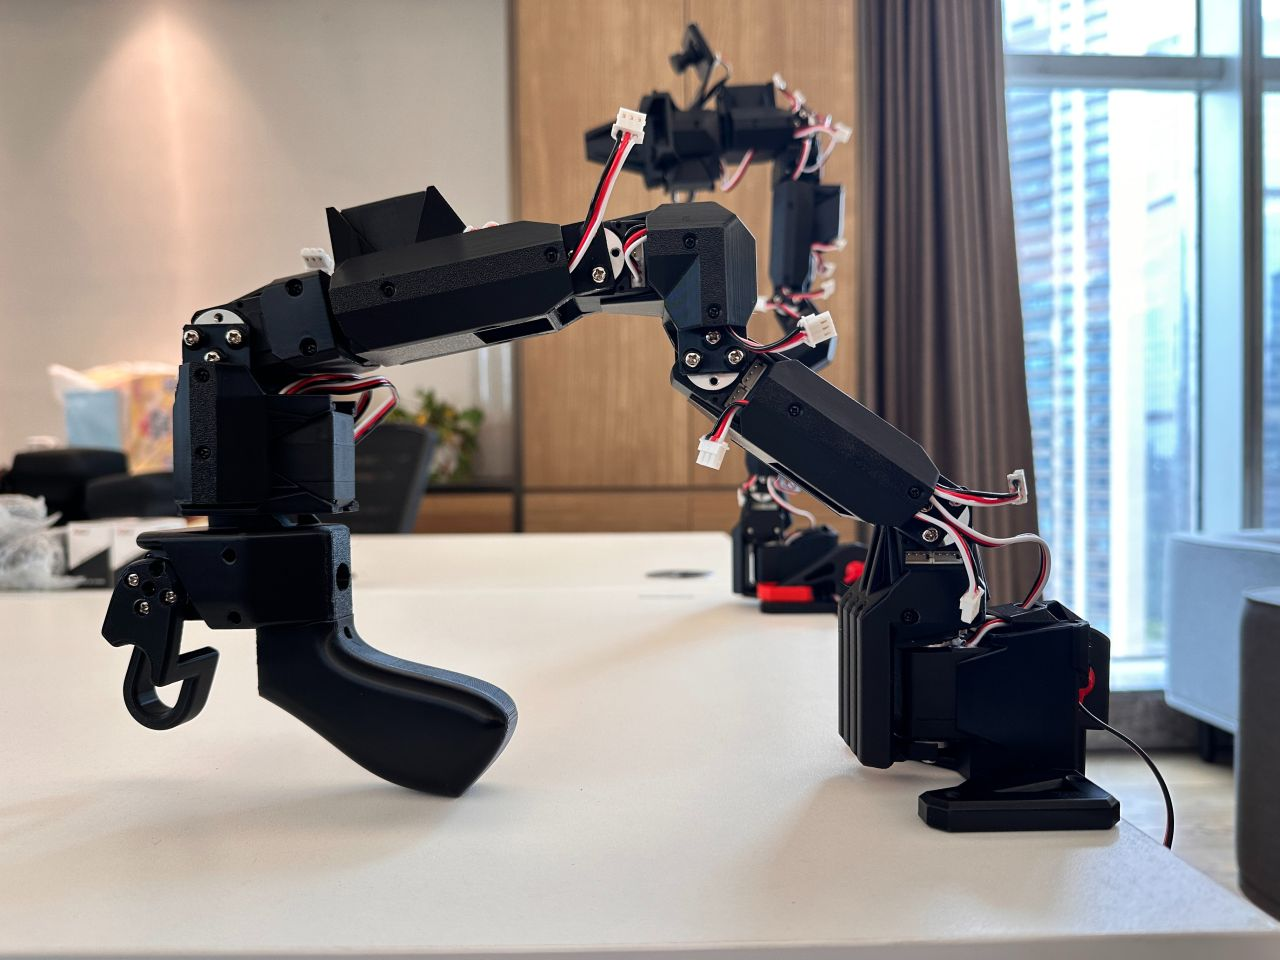
Robotic arm prototype on a workbench
001SHENZHEN · 2026

ROBOTICS / PHYSICAL AI / HARDWARE

Physical
intelligence.

Things being built, tested, and taken out of the screen.

↓
01THE PREMISE

Machines that
have to work.

Human motion, robot motion, and the data between them.

A live visual record of robotics and physical-AI systems in progress.

02CURRENT SYSTEMS
FOUR PERSONAL SIGNALS
01 / 04POST ↗

UMI gripper

Human demonstration → structured robotics data

A tabletop loop connecting gripper opening, camera motion, and object interaction.
POST ↗

Human → ORCA

Retargeting human hand motion to a 17-actuator robotic hand.
02 / 04
POST ↗

Wearable VLA

Stereo vision, SLAM, and 3D hand–object tracking.

03 / 04
POST ↗

Hand / object

Keeping the relevant object locked in clutter.

04 / 04
03CALIBRATION
HARDWARE / CONTROL
OPEN ON X ↗

Servo calibration

Every driver tested for position and current before final assembly.

A closer look at the checks that make physical systems reliable.
04FIELD NOTE
“Video alone is not enough.”
05THE LOOP
FROM HUMAN DATA TO ROBOT MOTION
01SEE

RGB / stereo / SLAM

02TRACK

hands / objects / pose

03RETARGET

human intent → joints

04ACT

control / feedback / repeat